Fuel for Robots: iLeeCo Launches Data Collection Platform for Physical AI

Fuel for Robots: iLeeCo Launches Data Collection Platform for Physical AI
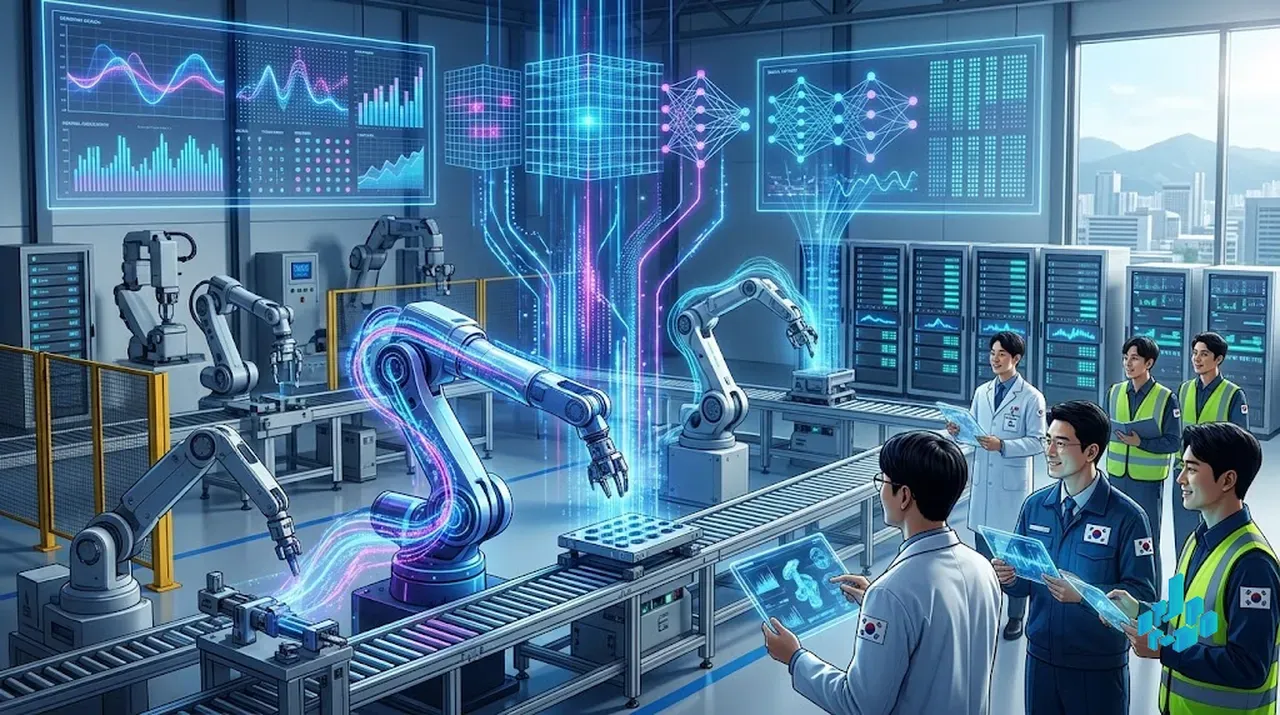
The primary bottleneck obstructing the evolution of autonomous robotics has been the severe scarcity of high-fidelity training datasets derived from the physical world. On October 26, 2026, South Korean enterprise iLeeCo addressed this deficit by unveiling the PHYDATUM platform. The system is architected to continuously harvest, aggregate, and standardize telemetry from industrial robots, indexing motion coordinates, operational cycles, hardware failures, and recovery processes.

The establishment of a standardized industrial robotics repository acts as a macroeconomic bridge bridging software and physical hardware. Physical AI laboratories finally acquire the annotated database of kinetic failures and behavioral patterns requisite for training embodied AI without the liability of destroying prohibitive factory equipment. The iLeeCo platform effectively functions as the ImageNet of robotics, instantiating a novel B2B market wherein industrial facilities can monetize raw production line data by licensing it to frontier multimodal model developers.

Источники: Hankyung | ETNews
Physical AIRoboticsiLeeCoSouth KoreaDatasets
« Back to News List